Oscar Low
Robotics Engineer who builds perception systems, with experience in simulation, state estimation, and semantics.
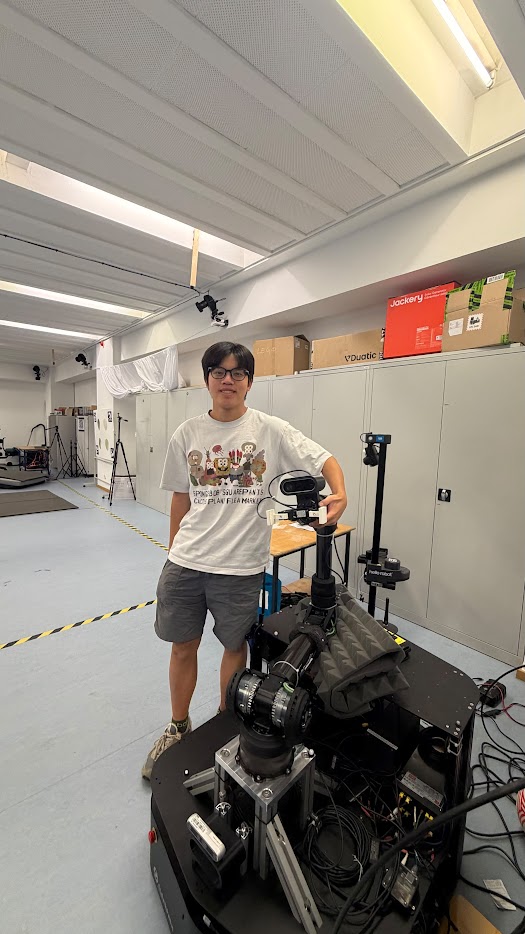
My nearly two years of research experience spans the full robotics-to-ML pipeline from real-time perception and SLAM on physical platforms to designing and training deep learning models from scratch. I'm looking forward to working with trending areas including VLAs and semantics.
Selected Work
01
BracketButler: Automation for Server Tasks
Deployed adaptable policies for ArUco perception, waypoint navigation, and hierarchical tray-transport tasks on the BracketBot platform.
2026
02
Robotics Researcher — Learning Systems Lab, TUM
Benchmarking + deployment of SLAM pipelines in simulation and real, and research in semantic perception as part of ESROP Global Fellowship.
2026
03
Computer Vision & Deep Learning Researcher — Lin Lab, UofT
Architected a Temporal Convolution Network for 3D zebrafish trajectory prediction, and a multi-view recording pipeline with water refraction correction.
2025
Skills
Languages
- Python
- C++
- MATLAB
- JavaScript
Robotics
- ROS
- Sensor fusion
- Isaac Sim
Mechanical
- 3D Printing
- Fusion 360
- Welding, Machining
Hardware
- [STM32 / Arduino]
- [KiCad]
- [CAN / I2C / SPI]